One gripper for a variety of workpieces.
Change gripper fingers with simple robot arm motion.
To handle a variety of workpieces with a single robot, common approaches include using a tool changer to replace the entire gripper or a dual-gripper setup to perform multiple tasks. While these solutions offer flexibility, they often require multiple grippers and can result in a larger, more complex system.
MotionAct Finger Changers offer another option: changing only the gripper fingers.
These mechanical fastening components enable gripper finger changes through simple robot arm movements.
By enabling automated finger changes to suit different workpieces while keeping the same gripper, MotionAct Finger Changers provide a flexible, cost-effective system.
Feature
Quick Finger Changes with Simple Robot Arm Motion
The gripper fingers can be locked and unlocked through simple robot arm movements.
Finger changes can be integrated into the product changeover sequence. This enables quick, automated finger changes while eliminating manual replacement.
Compatible with a Wide Range of Grippers
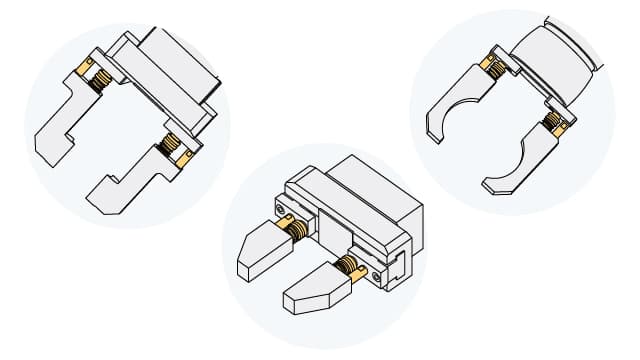
The mounting plate can be tailored to suit the gripper, allowing MotionAct Finger Changers to be used with a wide variety of grippers. Any gripper that can accommodate the clamping pin can be used.
With no need for a specific manufacturer or dedicated gripper, this provides a simpler, more cost-effective alternative to systems that replace the entire gripper.
Secure Mechanical Locking
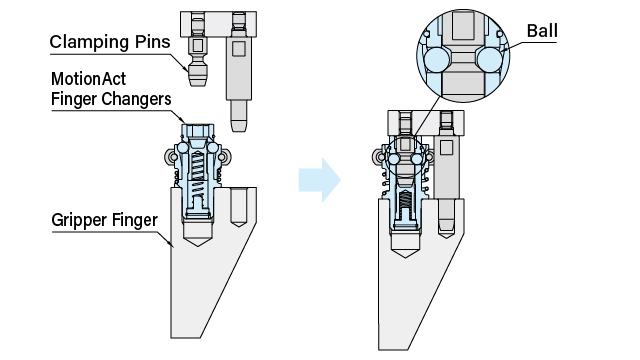
When the clamping pin is inserted into the Finger Changer, internal balls engage and securely retain the pin. The ball-and-taper mechanism locks the finger firmly in place and keeps it securely locked until release using the retaining pin and robot arm movement.
Built on IMAO’s expertise in mechanical fastening, the locking mechanism requires no electrical wiring or air piping to operate.
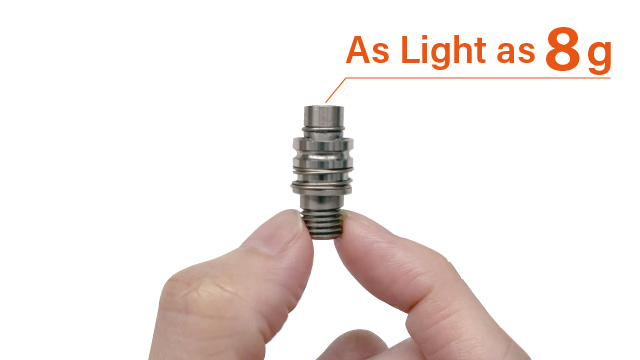
Compact and Lightweight for Small Robots
By changing only the gripper fingers instead of the entire gripper, the changeover system can be kept compact, providing greater flexibility in equipment layout.
The compact, lightweight system also minimizes the impact on robot payload capacity, making it well suited for small robots with limited payload.
APPLICATION EXAMPLE
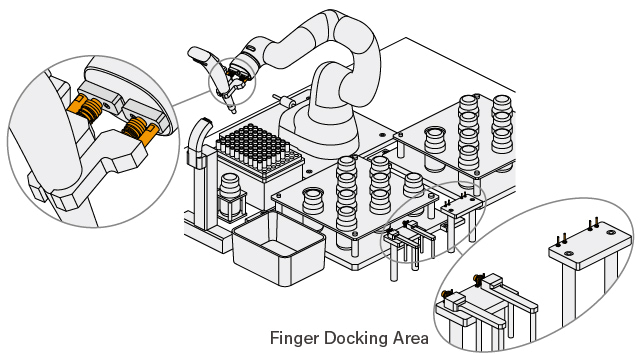
Gripper Finger Change in a Laboratory
Gripper fingers can be changed to suit the tools or workpieces being handled, enabling flexible automation of multiple tasks with a single small robot.
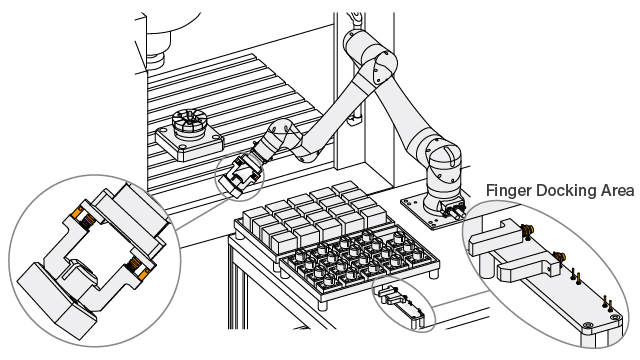
Gripper Finger Change for Machine Tending
Gripper fingers can be changed automatically to suit different workpieces, enabling automated machine tending for high-mix production.
Lineup
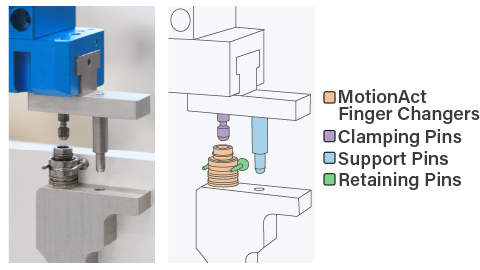
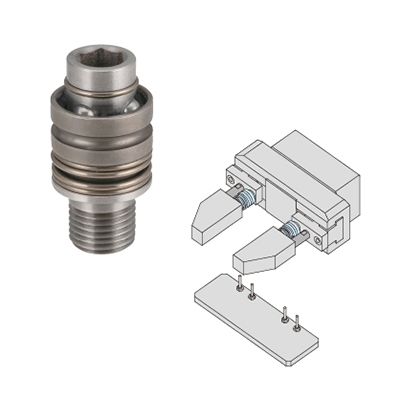
QMCF
MotionAct Finger Changers
- Mechanical locking units that receive and lock the Clamping Pin to secure the gripper finger to the gripper.
- The mechanical locking mechanism uses spring force and requires no air or electrical power.
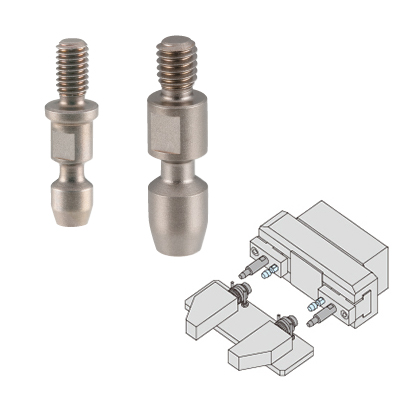
QMCFC
Clamping Pins
- Pins inserted into the Finger Changer.
- With a mounting plate designed to suit the gripper, they can be mounted on a wide range of grippers.
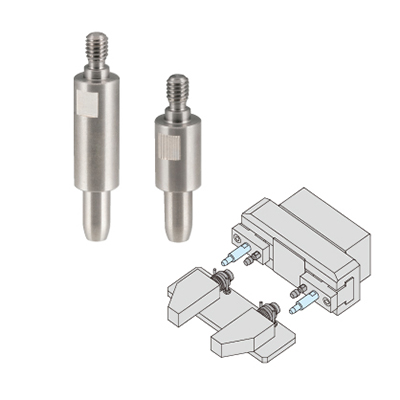
QMCFS
Support Pins
- Pins that support moment loads applied to the gripper finger.
- Using two Support Pins per finger improves positioning accuracy.
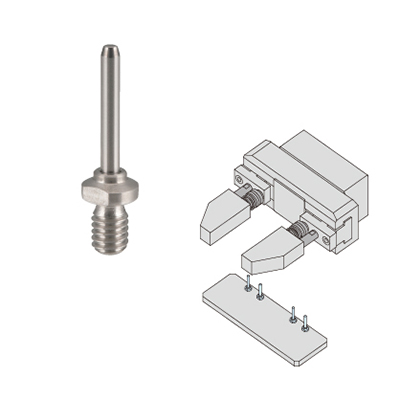
QMCFE
Retaining Pins
- Pins that engage the groove on the Finger Changer body to hold it in place.
- During removal, they provide a support point, allowing the Finger Changer to be disengaged through robot arm movement.
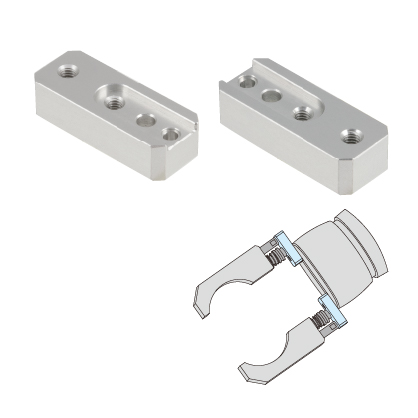
QMCFP
Mounting Plates for COBOTTA
- Mounting plates designed for installing the pins on COBOTTA’s optional electric gripper.
- For use with the QMCF0411-15-SUS Finger Changer.
COBOTTA is a registered trademark of DENSO WAVE INCORPORATED.
You may also like

One-Touch Tool Changers
Quick manual tool changers for collaborative robots
Learn More about One-Touch Tool Changers
Pneumatic Clamping Fasteners
Automated quick fasteners for machine changeover
Learn More about Pneumatic Clamping Fasteners